ORCA Dexterity
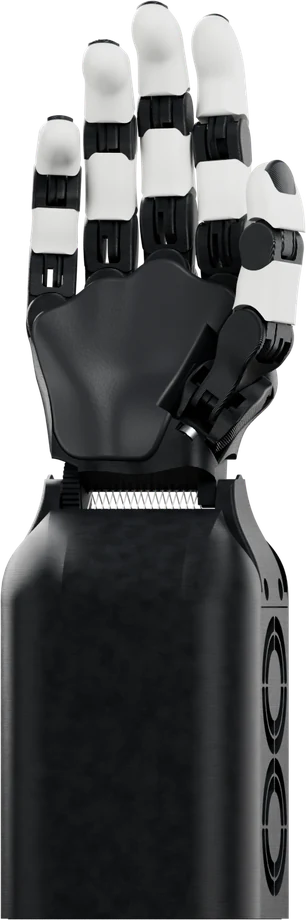
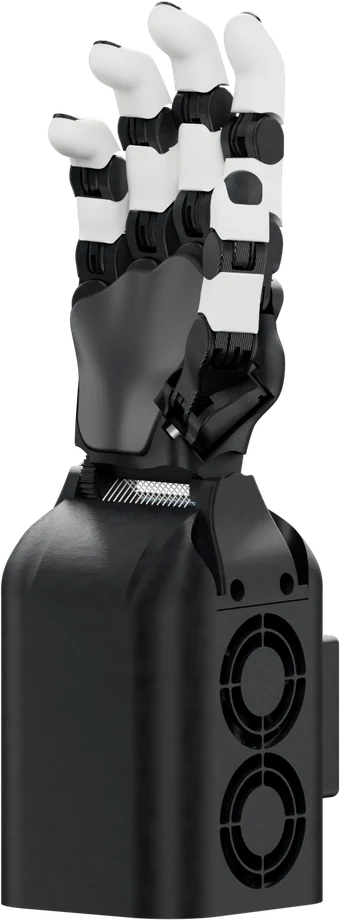
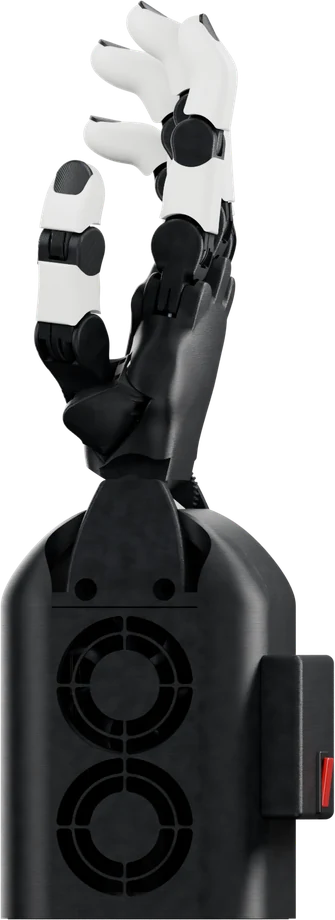
OrcaHand Dexterous Hand
The v2.1 Base is a five-finger end effector for grasping and dexterous manipulation research. It combines 16 tendon-driven finger degrees of freedom with one powered wrist axis and supports Python control and MuJoCo simulation.
Specifications and configuration
- Model
- v2.1 Base
- Active degrees of freedom
- 17
- Mass
- 1.3 kg
- Dimensions (H × W × D)
- 330 × 93 × 96 mm
- Power supply
- 12 V / 5 A
- Interface
- USB-C
- Mounting flange
- ISO 9409-1
Product categories
Product information
Official ORCA Dexterity datasheet for the v2.1 Base configuration shown here.