Sharpa Wave Series
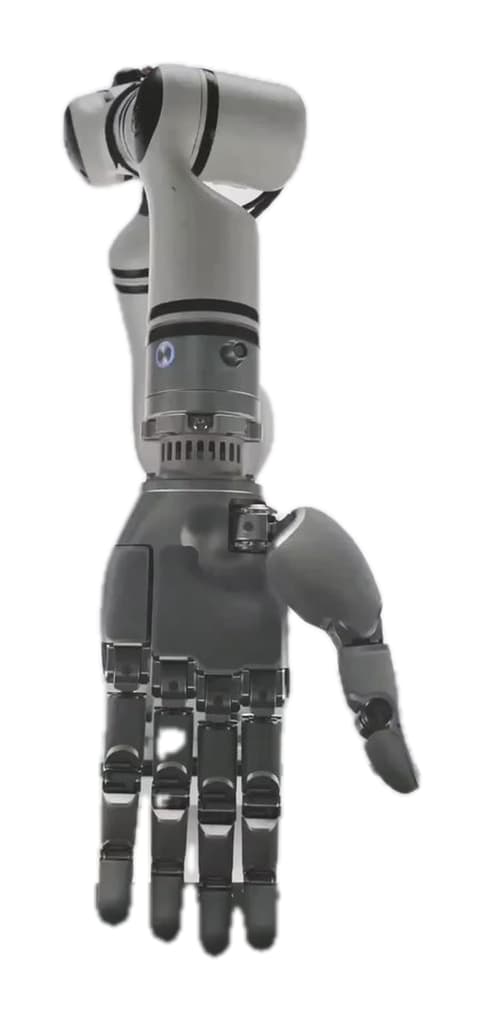
Sharpa Wave
Five-finger dexterous hand, 22 active DoF, 1.3kg, 208×90×50mm, 20N fingertip force, 150N grip force, 40kg payload, 240×240 tactile resolution @180fps
Inquire about this variantFull technical details
- Weight
- 1.3 kg
- Dimensions
- 208 mm × 90 mm × 50 mm
- Active DOF
- 22
- Drive system
- 22 in-house actuator modules
- Lateral range of four fingers
- ±20°
- Minimum grasp diameter
- 10 mm
- Payload
- 40 kg
- Grip force
- 150 N
- Fingertip force
- 20 N
- Operating frequency
- 4 Hz
- Operating voltage
- 18–28 V
- Static current
- 0.75 A @ 20 V
- Operating temperature
- 0°C to 45°C
- Fingertip position repeatability
- ±1 mm
- Rated service life
- Over 1,000,000 cycles
- Tactile resolution
- 240×240
- Force resolution
- 0.02 N
- Maximum tactile load
- 50 N
- Force detection range
- 0–30 N
- Spatial resolution
- 1 mm
- Frame rate
- 180 fps
- Raw image output
- Supported
- Inference mode
- Host + onboard inference
- Tactile sensor life
- Over 100,000 presses
22 active degrees of freedom
- Palm-width-to-hand-length ratio of approximately 0.618 for human-sized tools
- Anthropomorphic design with 22 active DOF
- ±20° lateral movement of four fingers and 10 mm minimum grasp diameter
Dynamic Tactile Array (DTA)
- Fingertips sense pressure, slip, force changes and contact position
- Closed-loop adaptation adjusts grip, pose and force as objects move, deform or become occluded
- Six-axis force/torque sensing with 20 ms latency
Reliability and development ecosystem
- 2.5 million press cycles, 4,000 m friction travel and 3,200 mechanical shocks at 30 g
- Protective fist response in 0.10 s and over 1,000 hours of extreme-temperature cycling
- ROS 2, MuJoCo, Isaac Sim and SharpaPilot SDK
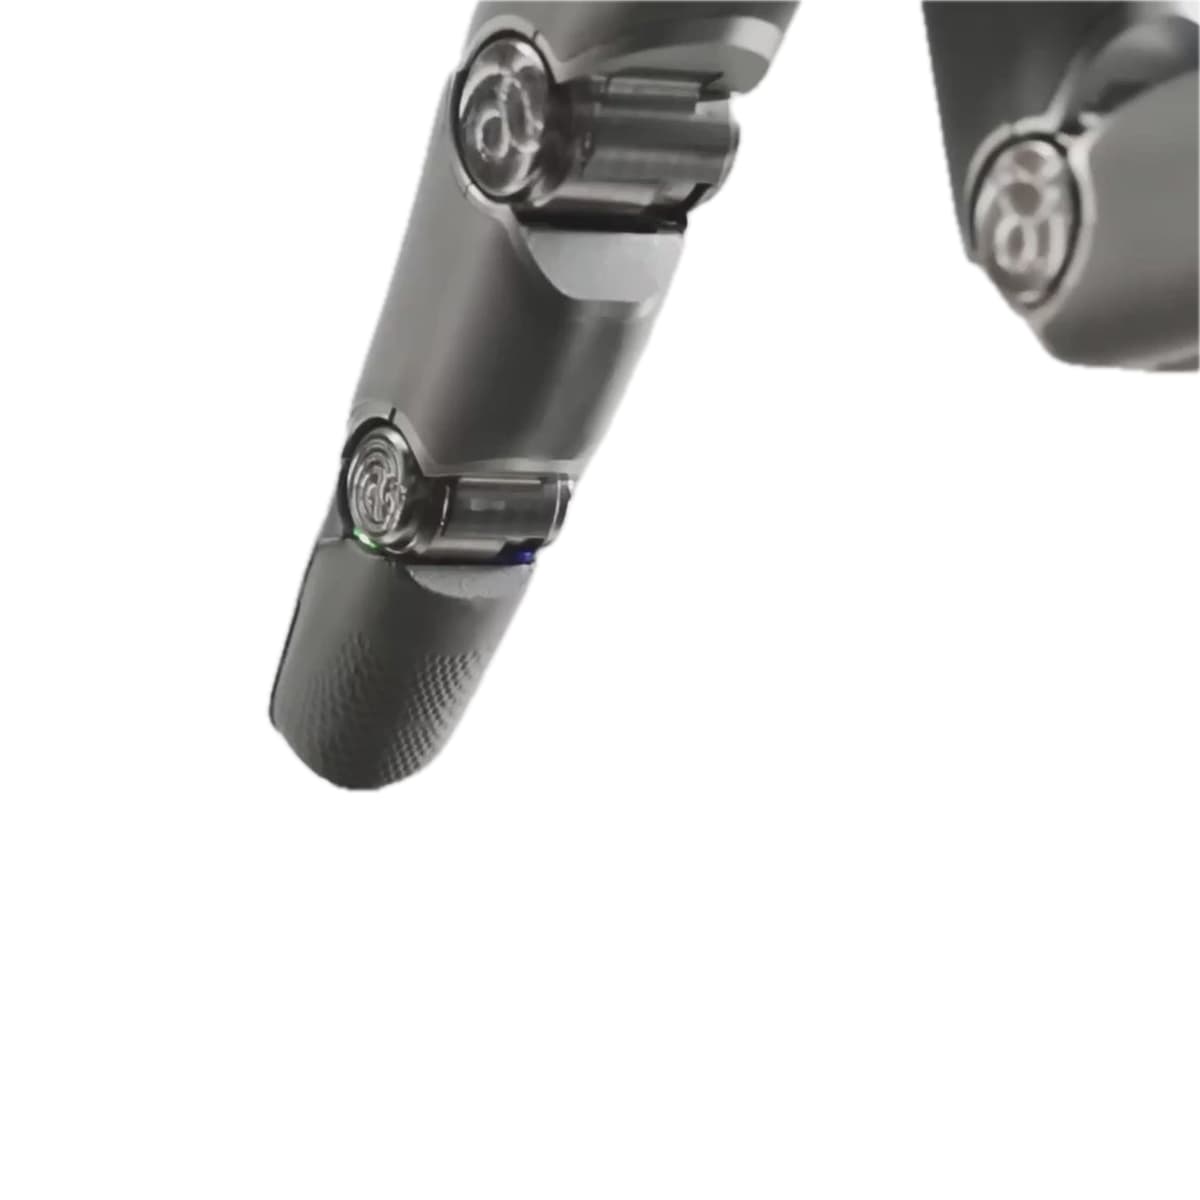
Sharpa Wave SE
Streamlined tactile edition of Wave, 22 active DoF, 12N fingertip force, 90N grip force, 24kg payload, 60×60 tactile resolution @30fps, on-board inference
Inquire about this variantFull technical details
- Weight
- 1.3 kg
- Dimensions
- 208 mm × 90 mm × 50 mm
- Active DOF
- 22
- Payload
- 24 kg
- Grip force
- 90 N
- Fingertip force
- 12 N
- Operating frequency
- 2 Hz
- Tactile resolution
- 60×60
- Force resolution
- 0.05 N
- Spatial resolution
- 2 mm
- Frame rate
- 30 fps
- Raw image output
- Not supported
- Inference mode
- Onboard inference
- Force detection range
- 0–30 N
- Fingertip position repeatability
- ±1 mm
Shared Wave mechanical design
- 22 active DOF, 1.3 kg weight and 208 × 90 × 50 mm dimensions
- ±20° lateral finger movement and 10 mm minimum grasp diameter
- Same mechanical reliability tests as Wave
Cost-sensitive integration
- 60×60 tactile resolution at 30 fps with onboard inference
- Raw image output is not supported
- 24 kg payload, 90 N grip force and 12 N fingertip force